
Risk-Aware Generation of Static Highway Scenarios for Autonomous Vehicle Testing
Generating realistic highway roads with controllable curvature, grade and vertical curves, then showing in CARLA that they are harder for controllers to drive.
Sole author: data pipeline, Topo-DiffRoad model, 3D/OpenDRIVE generator, and CARLA evaluation.
Generative AI-based Crash Data Augmentation for Enhancing Crash Frequency Modeling
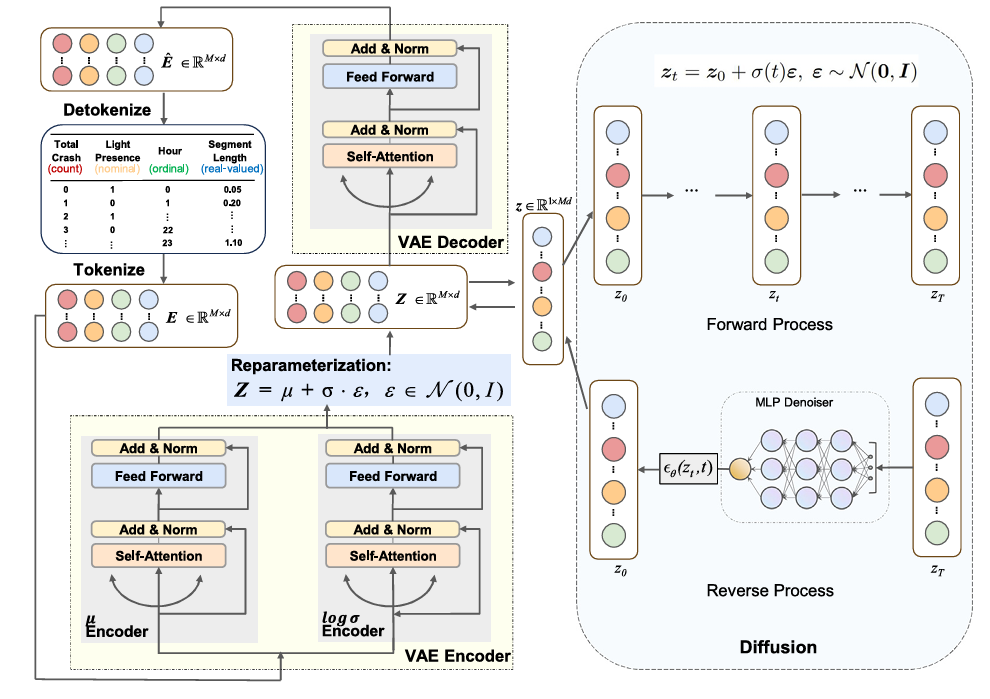
Proposed a hybrid VAE-Diffusion model (TabSyn) to augment imbalanced multi-type crash data, improving crash frequency prediction and high-risk segment identification.
Co-first author — led all analysis, manuscript writing, and journal correspondence.
Exploring the Impact of Active Transport Amenities on Lifestyle-Related Health Risks
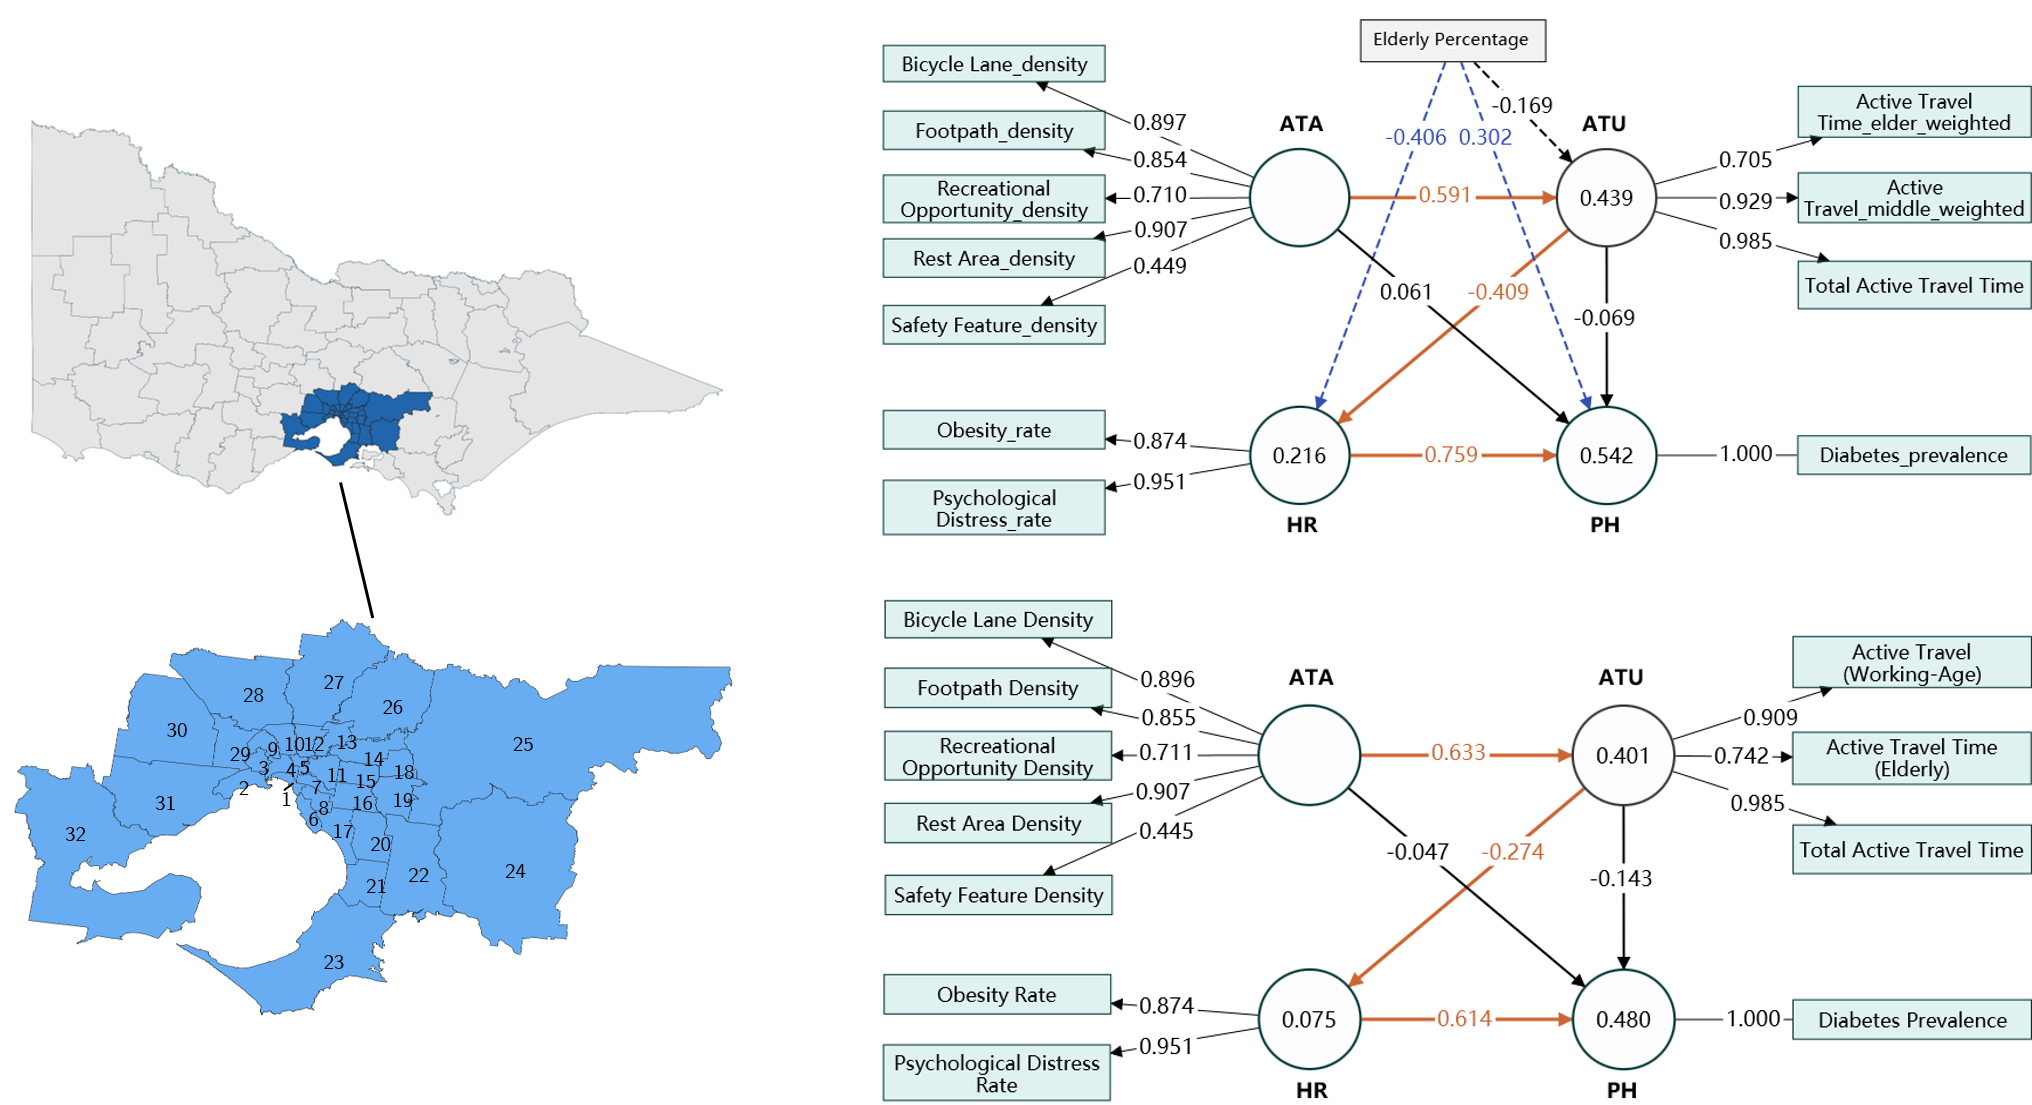
Do footpaths and bike lanes relate to diabetes, and if so, how? Using PLS-SEM on objective data from 32 local government areas in Victoria, Australia, I found the link is entirely indirect: more amenities → more walking and cycling → lower obesity and distress → lower diabetes prevalence.
First author: conceptualization, methodology, analysis, and original draft.
SG-CADVLM: Context-Aware Decoding for Safety-Critical Scenario Generation from Crash Reports
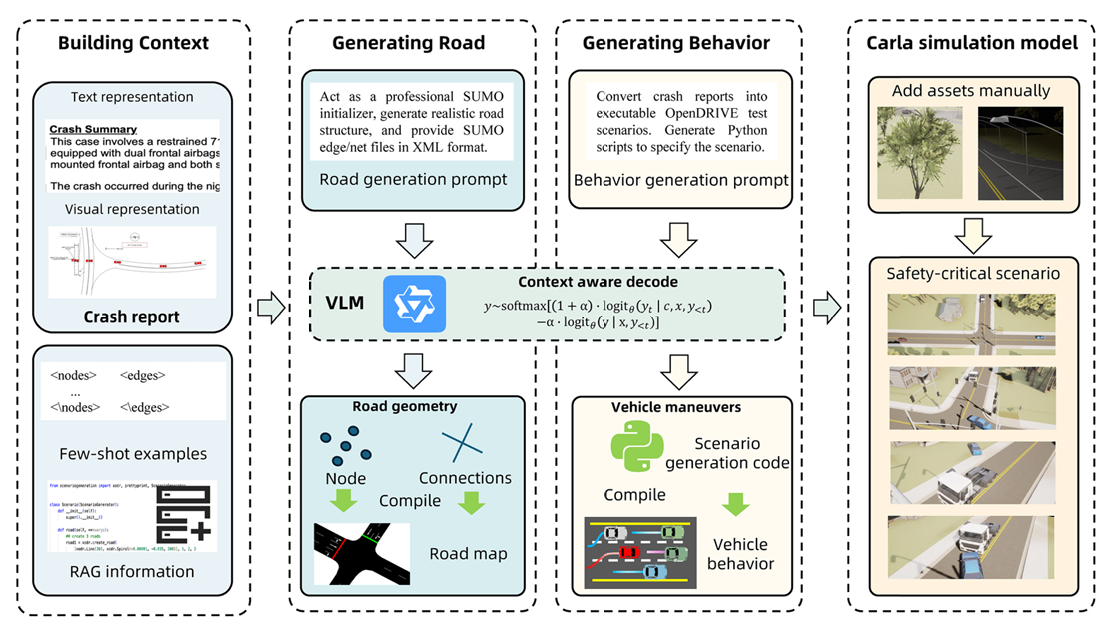
Vision-language models can turn crash reports into simulation scenarios, but they often fall back on generic priors and ignore the report, giving the wrong road layout and tamer collisions. SG-CADVLM uses context-aware decoding to keep the model faithful to the report and its diagram, and generates the road network and vehicle behavior together as files that run in CARLA. On 109 NHTSA crash reports, 88.1% of generated scenarios were critical or high-risk, versus 31.2% for the Omnitester baseline.